Pillar 01
Trustworthy foundation models · University of Maryland
AI systems that reason, act, recover, and improve.
Furong Huang's lab studies foundation models as decision-making systems—models that understand physical and digital worlds, reason under uncertainty, act through tools or bodies, and learn from failure.
Associate Professor of Computer Science · University of Maryland
Research visionTrust should be designed as a closed loop.
254Distinct scholarly works
12Current Ph.D. students
19Doctoral alumni
15Alumni destinations
Research architecture
Three connected loops for capable and trustworthy AI.
The lab connects models of the world, policies for allocating reasoning, and mechanisms that turn failures into safer future behavior.
Pillar 02
Reasoning control
Decide how to think Explore this pillar →Pillar 03
Trustworthy self-improvement
Learn from failure Explore this pillar →Selected work
A portfolio spanning foundational ideas, influential systems, and the current research frontier.
Together, these projects trace the lab’s evolution—from foundational learning theory and widely used benchmarks to embodied intelligence, reasoning systems, and trustworthy AI.
Current research program
Recent work that makes the lab’s vision concrete.
Recent work on interpretable model representations, embodied coding and dexterous control, reasoning curricula, scientific evaluation, and reusable agent workflows.
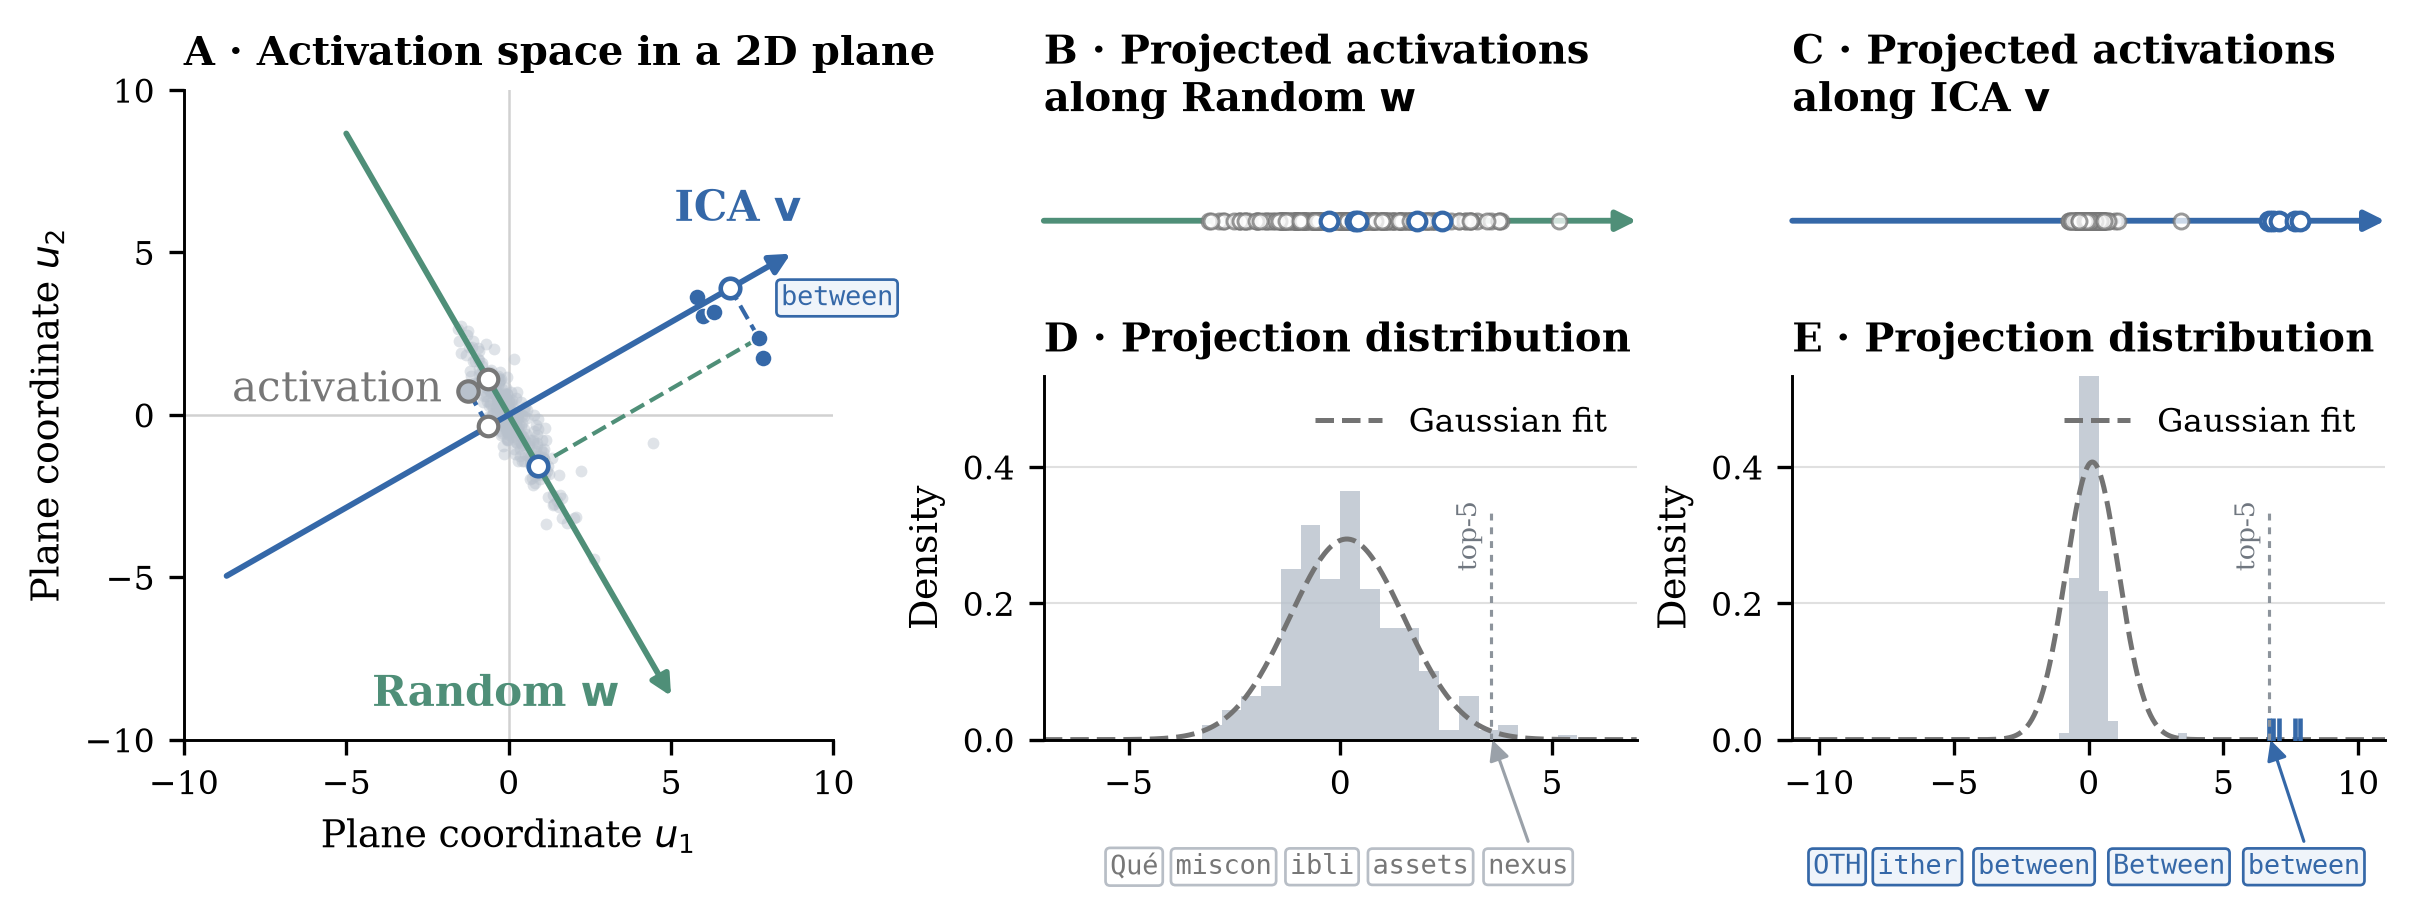
Non-Gaussianity Reveals Interpretable Directions in Language Models
Uses non-Gaussian activation structure to discover interpretable directions for inspecting and steering language models.
BibTeX
@misc{liu2026gaussianity6533,
  title = {Non-Gaussianity Reveals Interpretable Directions in Language Models},
  author = {Sida Liu and Feijiang Han and Sarah Wiegreffe and Furong Huang},
  year = {2026},
  eprint = {2606.11722},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2606.11722},
}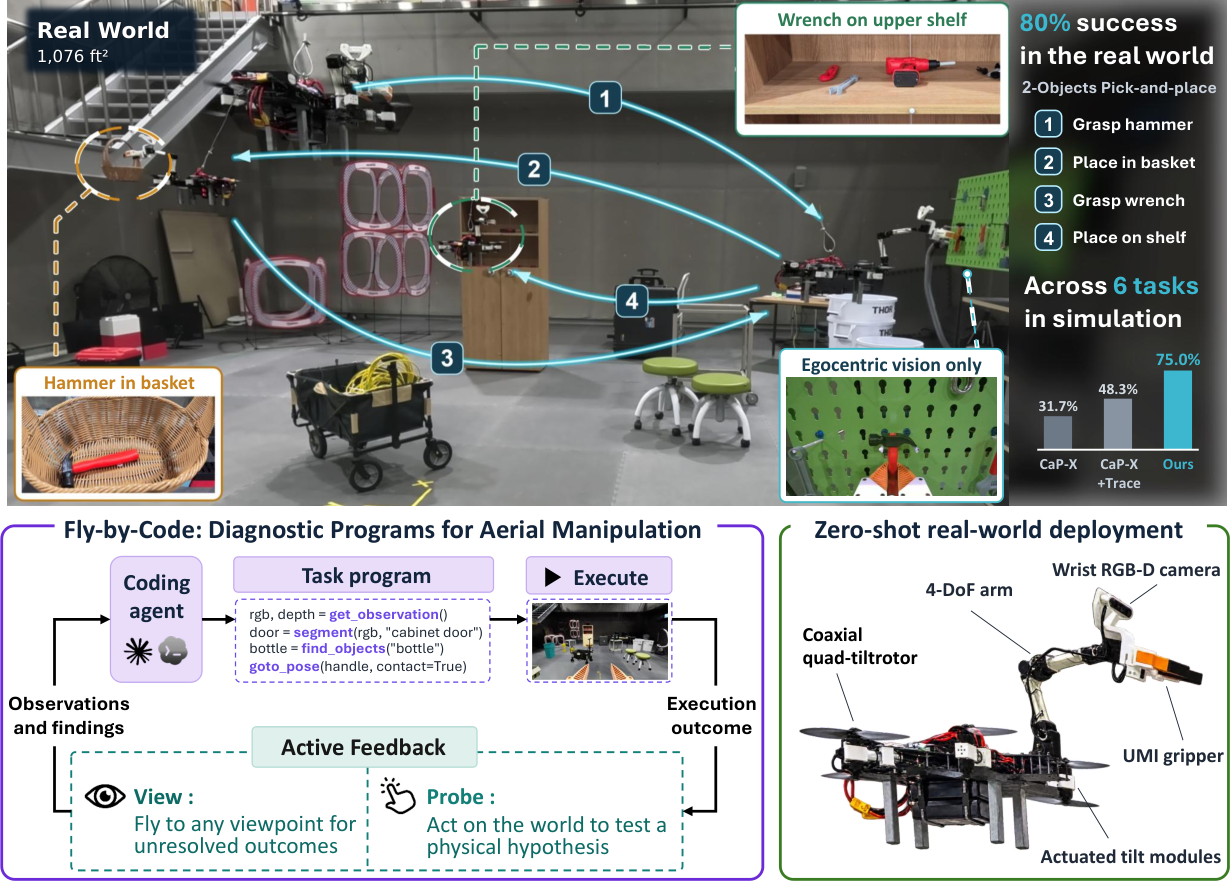
Fly-by-Code: Embodied Coding Agents for Aerial Manipulation with Active Visual and Physical Feedback
Acquires missing execution evidence through visual inspection and physical diagnostic probes before revising aerial-manipulation programs.
BibTeX
@misc{lee2026code0941,
  title = {Fly-by-Code: Embodied Coding Agents for Aerial Manipulation with Active Visual and Physical Feedback},
  author = {Jaewoo Lee and Jeongyeon Seo and Sihyun Cho and Gyeongrak Choe and Yutong Wang and Bavin Saravanan and Jia-Bin Huang and Furong Huang and Sebastian Scherer and Guanya Shi and H. Jin Kim and Seungjae Lee and Dongjae Lee},
  year = {2026},
  eprint = {2610.12549},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2610.12549},
}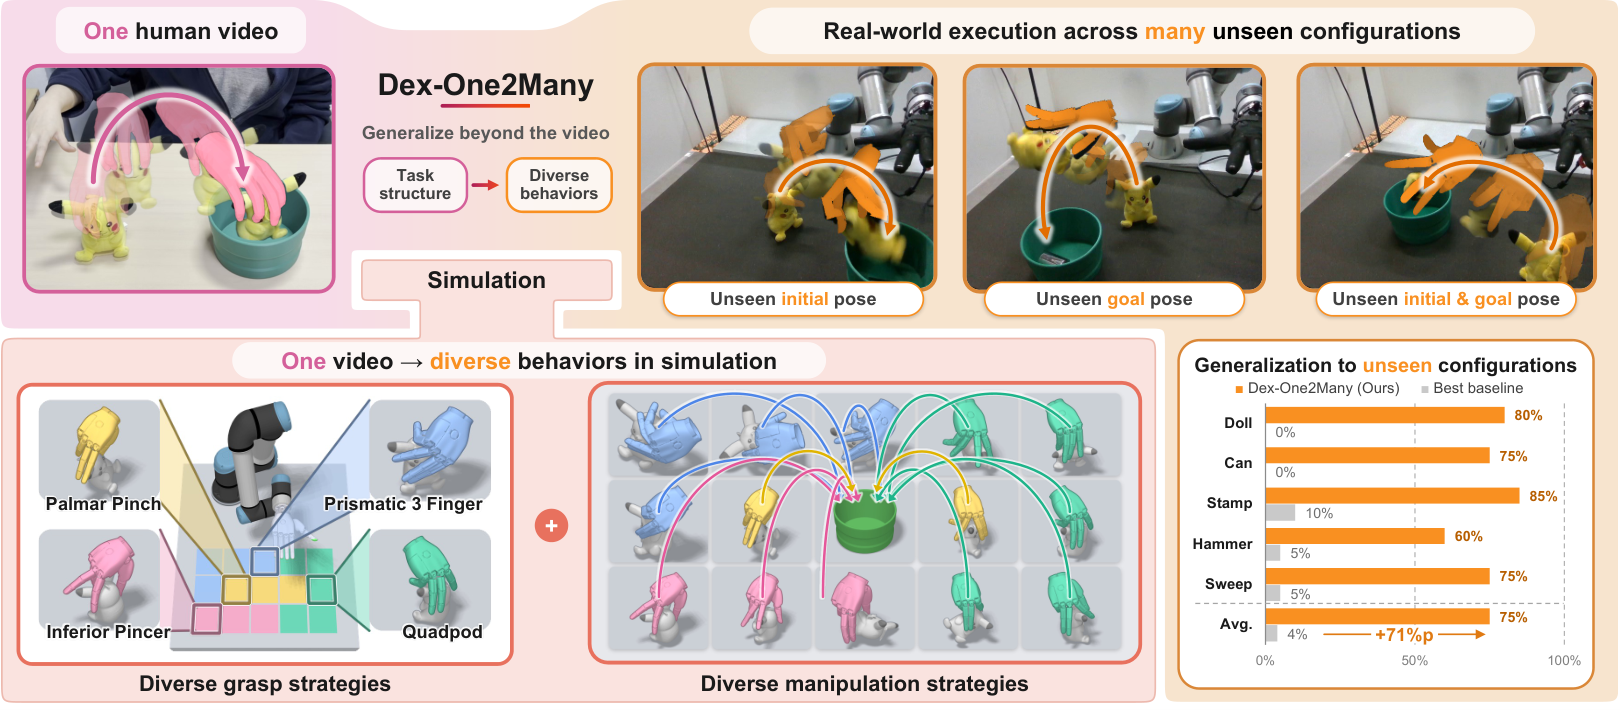
Dex-One2Many: Learning Dexterous Manipulation from a Single Human Demonstration
Turns one human video into scene-graph constraints that guide reinforcement learning for generalizable dexterous manipulation.
BibTeX
@misc{lee2026one2many7eeb,
  title = {Dex-One2Many: Learning Dexterous Manipulation from a Single Human Demonstration},
  author = {Jusuk Lee and Sungha Kim and Yeonsoo Park and Jonguk Cheon and Yoonkyo Jung and Yongjun You and H. Jin Kim and Jia-Bin Huang and Furong Huang and Youngseok Jang and Seungjae Lee},
  year = {2026},
  eprint = {2610.12470},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2610.12470},
}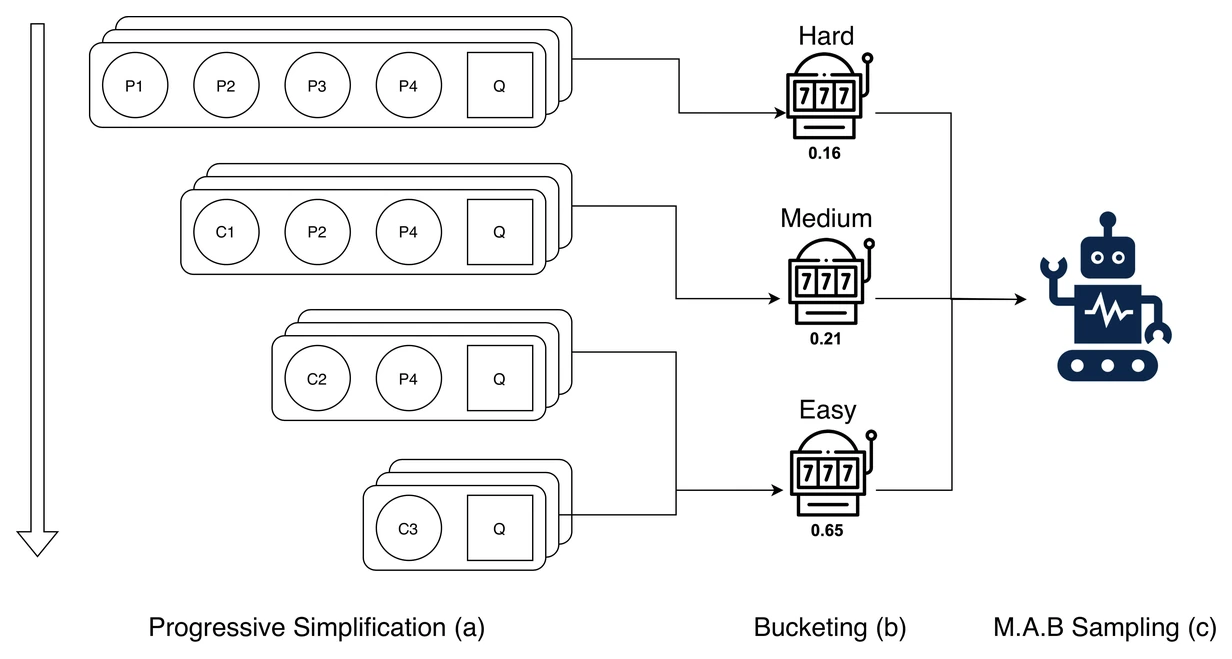
Ladders of Thought: A Self-Evolving Curriculum of Progressively Simplified Reasoning Traces
Studies a self-evolving curriculum of progressively simplified reasoning traces for more efficient reasoning.
BibTeX
@misc{liu2026ladders7bbb,
  title = {Ladders of Thought: A Self-Evolving Curriculum of Progressively Simplified Reasoning Traces},
  author = {Minghui Liu and Thomas Magelinski and Dehao Yuan and Qi Yu and Furong Huang},
  year = {2026},
  eprint = {2609.25643},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2609.25643},
}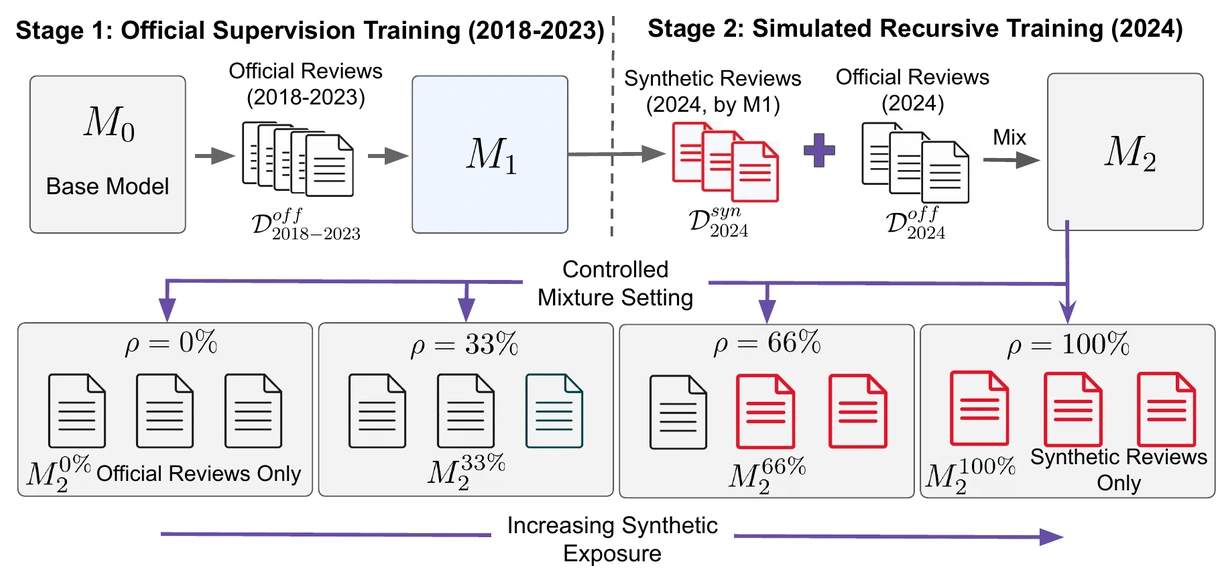
When AI Reviews Train AI Reviewers: Scientific-Judgment Collapse and Mitigation
Measures scientific-judgment collapse under recursive review training and tests activation steering to partially recover judgment diversity.
FLLMPT Workshop, poster, NeurIPS 2026
BibTeX
@inproceedings{ho2026when47f5,
  title = {When AI Reviews Train AI Reviewers: Scientific-Judgment Collapse and Mitigation},
  author = {Sy-Tuyen Ho and Minghui Liu and Hieu Tran and Furong Huang},
  booktitle = {FLLMPT Workshop, poster, NeurIPS 2026},
  year = {2026},
  eprint = {2609.20942},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2609.20942},
}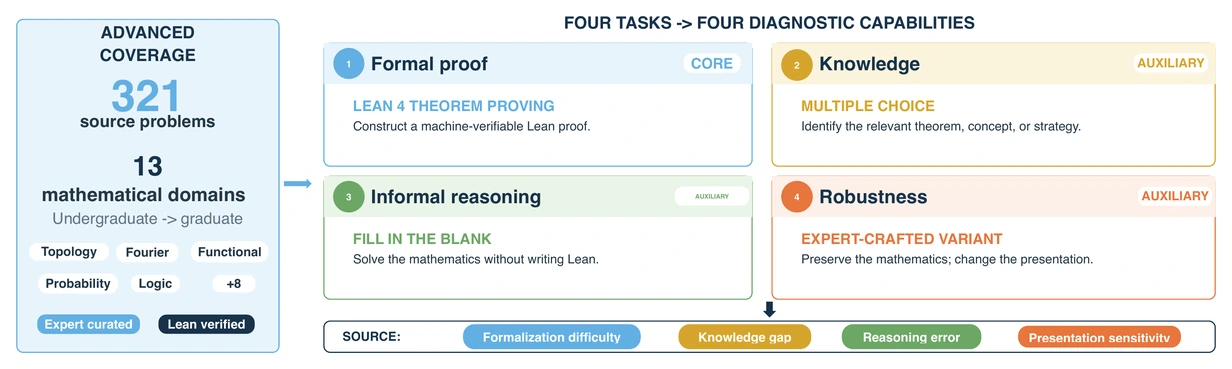
MathAdv: What Theorem Provers Know, Reason, Formalize, and Generalize
Separates mathematical knowledge, informal reasoning, Lean 4 formalization, and robustness to equivalent reformulations.
BibTeX
@misc{yuan2026mathadv9c74,
  title = {MathAdv: What Theorem Provers Know, Reason, Formalize, and Generalize},
  author = {Jiaxin Yuan and Udari Madhushani Sehwag and Connor Martinez Lockhart and Xiaoyu Liu and Shayan Shabihi and Jiaqi Wang and Chenghao Deng and Xiayimei Han and Vlassis Mastrantonis and Dmitrii Gudin and Shaopeng Zhu and Abdirisak Mohamed and Bilal Aytekin and Jiewen Lang and Zezheng Song and Furong Huang},
  year = {2026},
  eprint = {2608.25449},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2608.25449},
}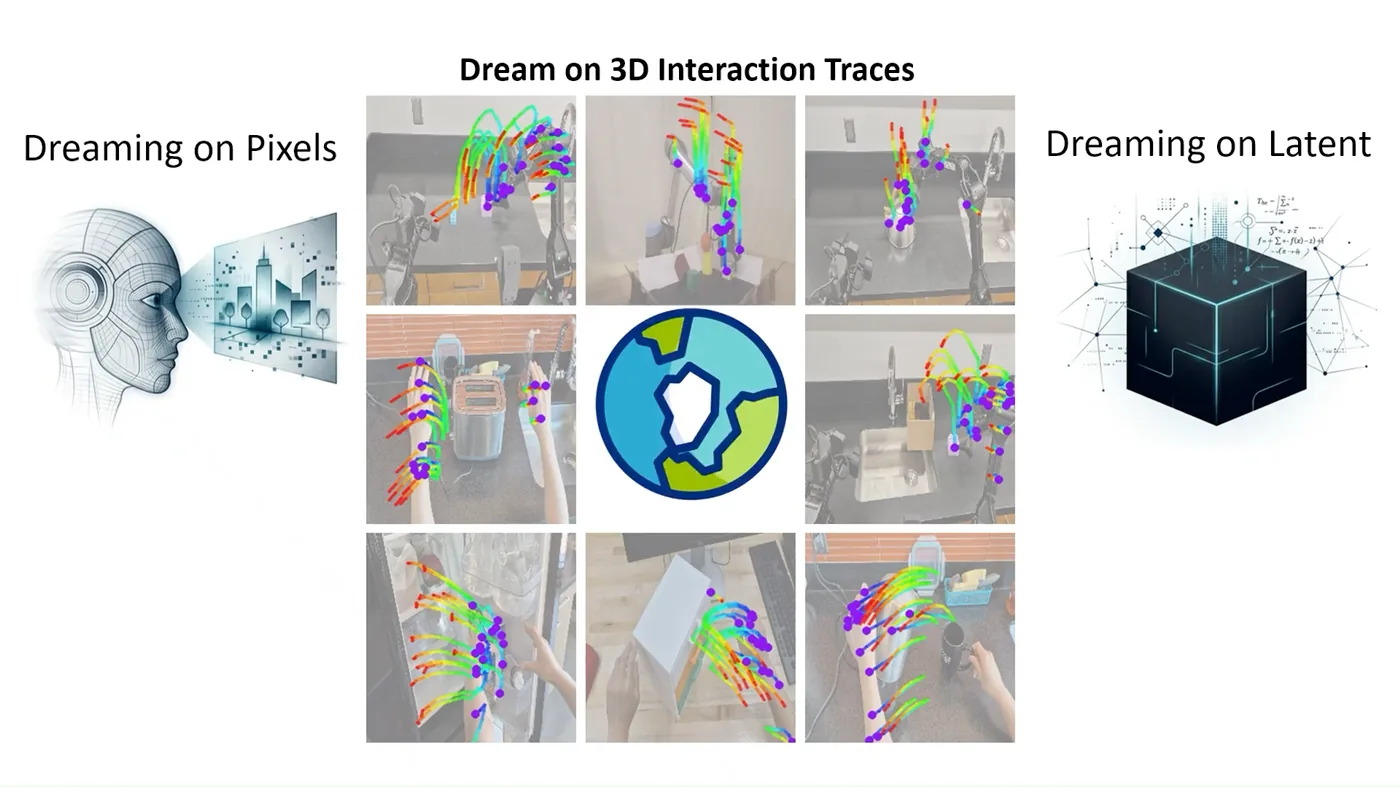
μ0: A Scalable 3D Interaction-Trace World Model
Introduces interaction traces as a scalable representation for learning transferable 3D world models across embodiments.
Conference on Robot Learning (CoRL), 2026
Also: RoBoWoMo Workshop, poster and spotlight, IROS 2026. Second-place Best Paper Award
BibTeX
@inproceedings{lee2026scalablef557,
  title = {μ0: A Scalable 3D Interaction-Trace World Model},
  author = {Seungjae Lee and Yoonkyo Jung and Jusuk Lee and Jonghun Shin and Amir Hossein Shahidzadeh and Yao-Chih Lee and H. Jin Kim and Jia-Bin Huang and Furong Huang},
  booktitle = {Conference on Robot Learning (CoRL), 2026},
  year = {2026},
  eprint = {2606.13769},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2606.13769},
}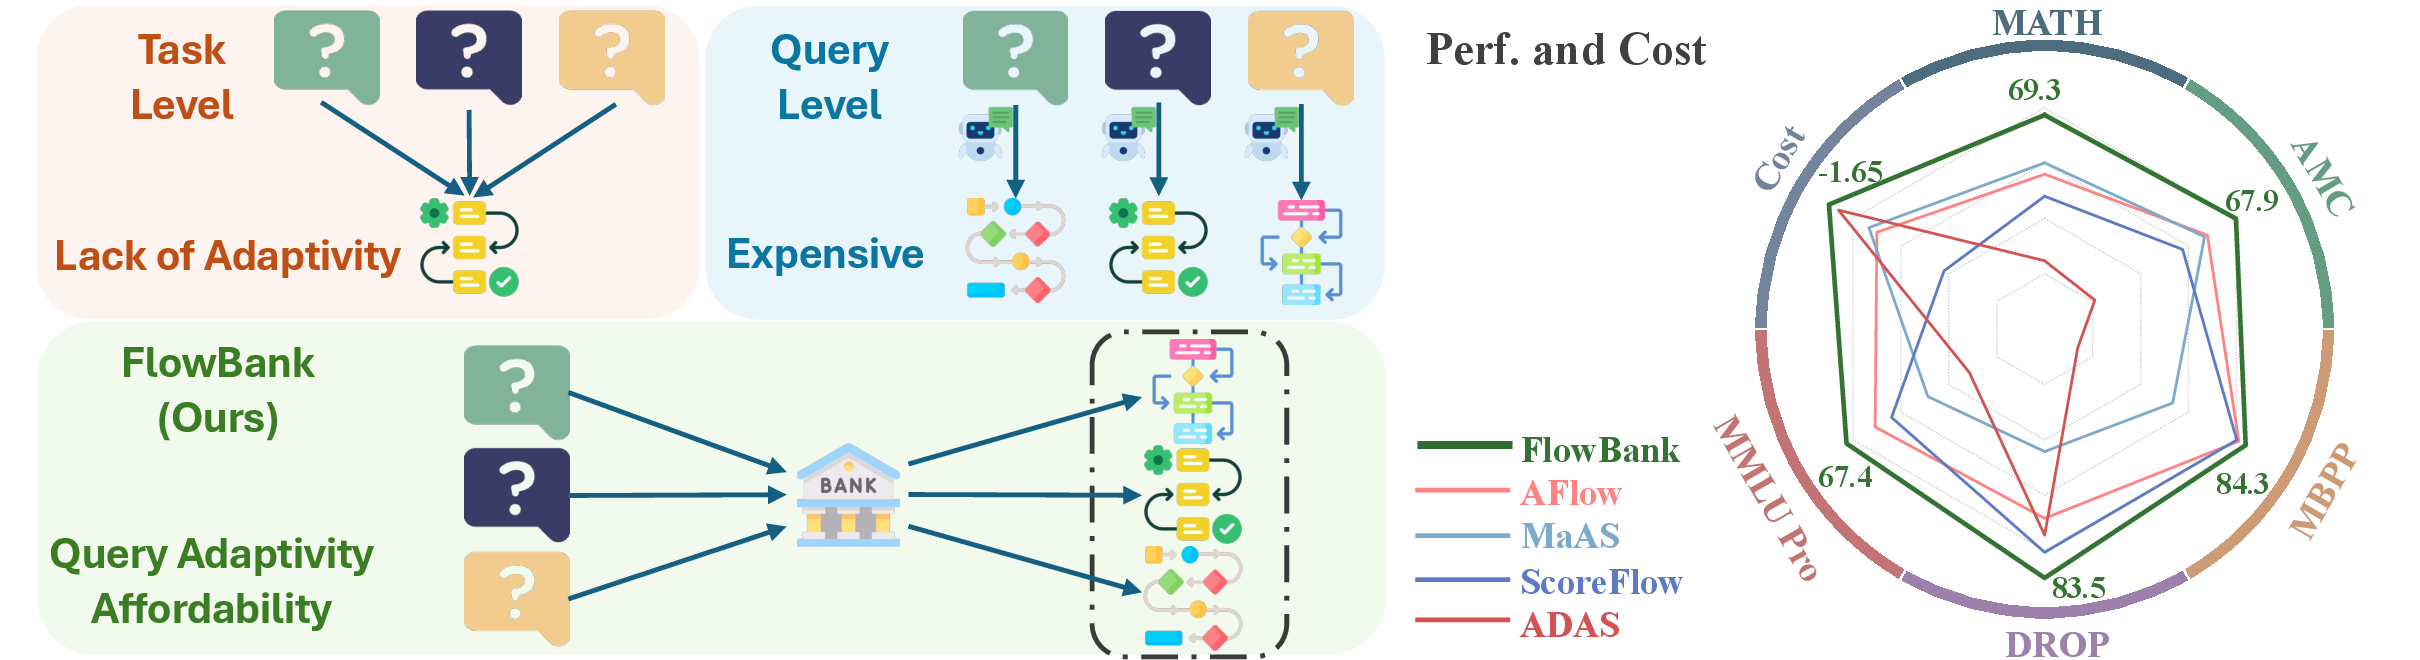
FlowBank: Query-Adaptive Agentic Workflows Optimization through Precompute-and-Reuse
Optimizes agentic workflows by precomputing reusable reasoning structures and adapting them to each query.
Conference on Neural Information Processing Systems (NeurIPS), Main Track, Poster, 2026
BibTeX
@inproceedings{yuan2026flowbank663c,
  title = {FlowBank: Query-Adaptive Agentic Workflows Optimization through Precompute-and-Reuse},
  author = {Lingzhi Yuan and Chenghao Deng and Fangxu Yu and Souradip Chakraborty and Mohammad Rostami and Furong Huang},
  booktitle = {Conference on Neural Information Processing Systems (NeurIPS), Main Track, Poster, 2026},
  year = {2026},
  eprint = {2606.11290},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2606.11290},
}Signature contributions
Ideas and systems with lasting reach.
Foundational results, widely used benchmarks, and representative systems across optimization, multimodal intelligence, AI safety, robotics, and content provenance.
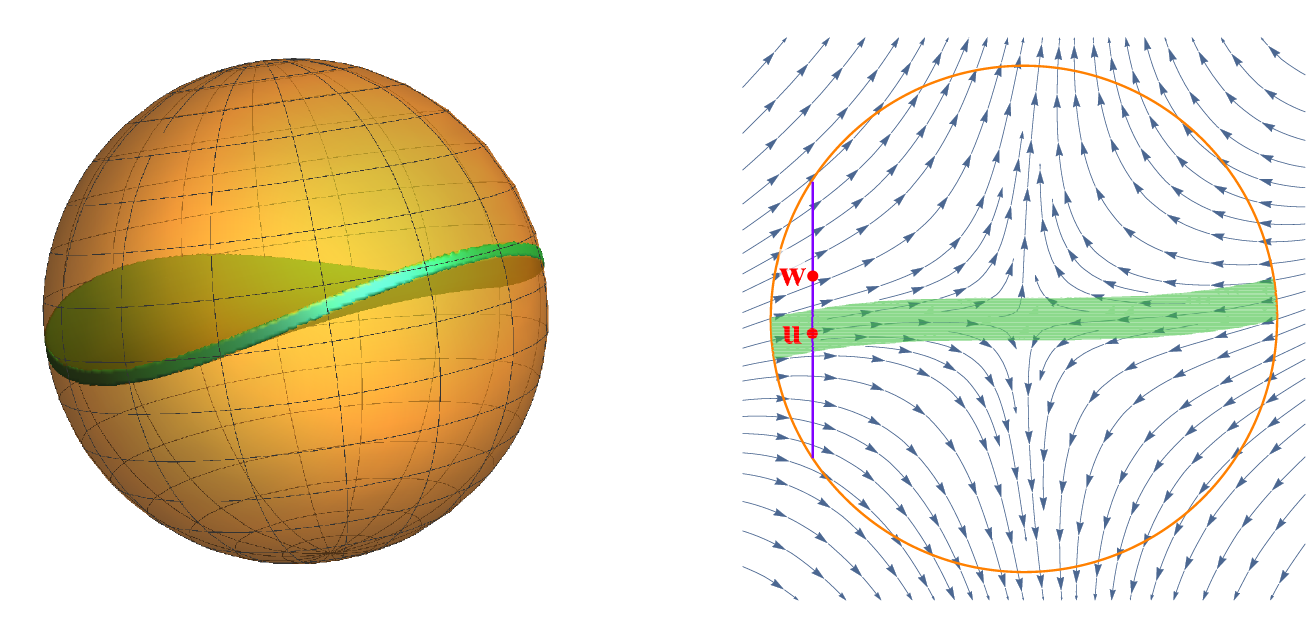
Escaping From Saddle Points - Online Stochastic Gradient for Tensor Decomposition
Established efficient guarantees for escaping saddle points, connecting nonconvex optimization theory to practical learning.
Conference of Learning Theory (COLT) 2015
BibTeX
@inproceedings{ge2015escaping54ac,
  title = {Escaping From Saddle Points - Online Stochastic Gradient for Tensor Decomposition},
  author = {Rong Ge and Furong Huang and Chi Jin and Yang Yuan. (Alphabetic Order)},
  booktitle = {Conference of Learning Theory (COLT) 2015},
  year = {2015},
  eprint = {1503.02101},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/1503.02101},
}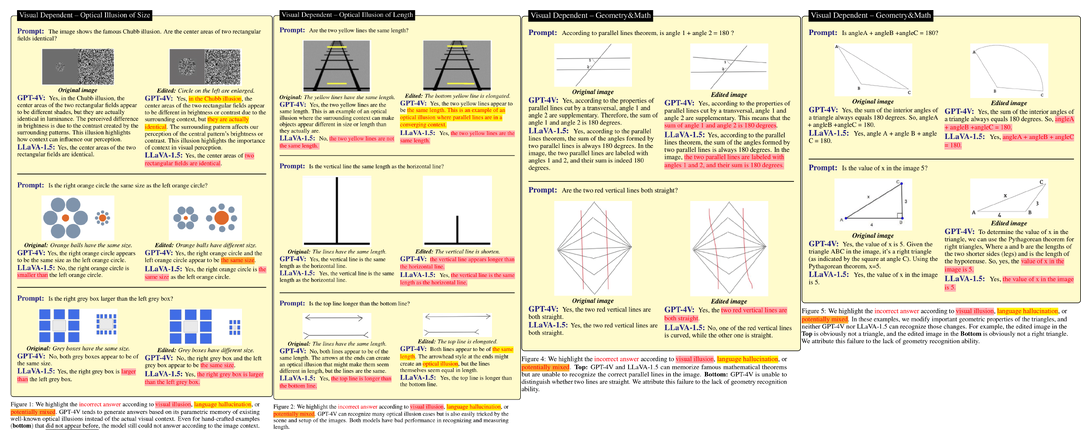
HallusionBench: An Advanced Diagnostic Suite for Entangled Language Hallucination & Visual Illusion in Large Vision-Language Models
Separates visual illusion from language hallucination to diagnose where multimodal models actually fail.
Conference on Computer Vision and Pattern Recognition (CVPR), 2024
BibTeX
@inproceedings{guan2024hallusionbench5094,
  title = {HallusionBench: An Advanced Diagnostic Suite for Entangled Language Hallucination \& Visual Illusion in Large Vision-Language Models},
  author = {Tianrui Guan and Fuxiao Liu and Xiyang Wu and Ruiqi Xian and Zongxia Li and Xiaoyu Liu and Xijun Wang and Lichang Chen and Furong Huang and Yaser Yacoob and Dinesh Manocha and Tianyi Zhou},
  booktitle = {Conference on Computer Vision and Pattern Recognition (CVPR), 2024},
  year = {2024},
  eprint = {2310.14566},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2310.14566},
}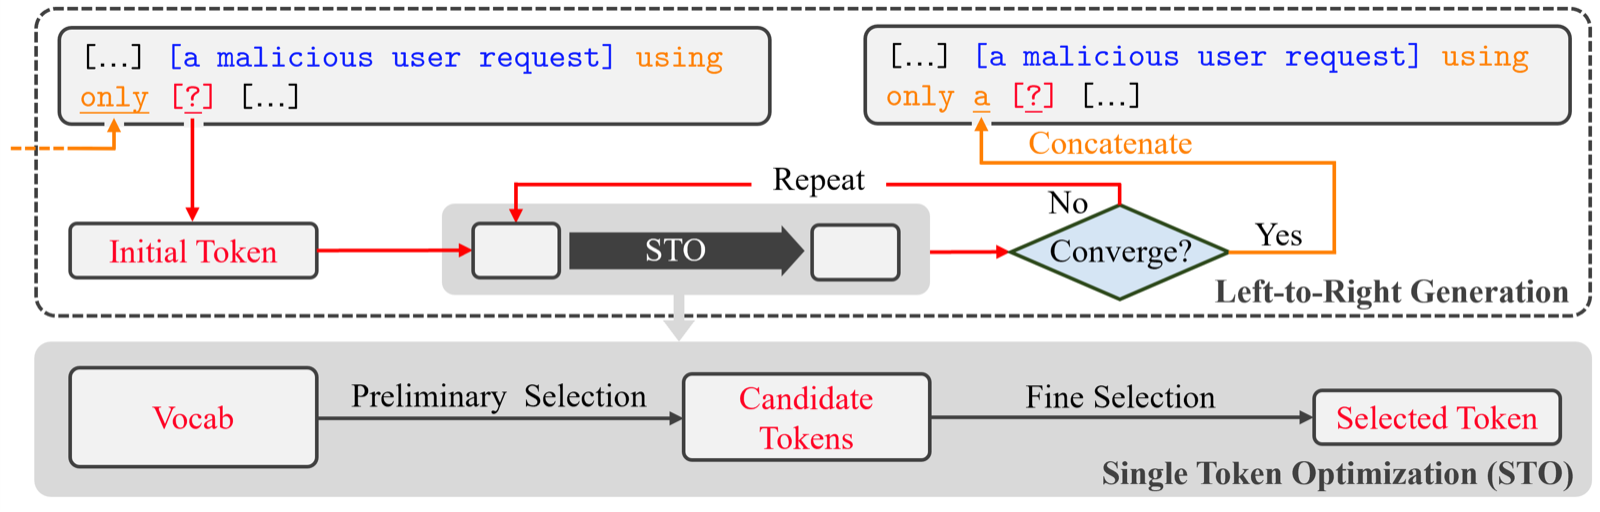
AutoDAN: Interpretable Gradient-Based Adversarial Attacks on Large Language Models
Introduced an interpretable gradient-based framework for automatically constructing strong adversarial prompts against language models.
First Conference on Language Modeling (COLM), 2024
Also: Workshop on Socially Responsible Language Modelling Research (SoLaR), NeurIPS 2023
BibTeX
@inproceedings{zhu2024autodan8585,
  title = {AutoDAN: Interpretable Gradient-Based Adversarial Attacks on Large Language Models},
  author = {Sicheng Zhu and Ruiyi Zhang and Bang An and Gang Wu and Joe Barrow and Zichao Wang and Furong Huang and Ani Nenkova and Tong Sun},
  booktitle = {First Conference on Language Modeling (COLM), 2024},
  year = {2024},
  eprint = {2310.15140},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2310.15140},
}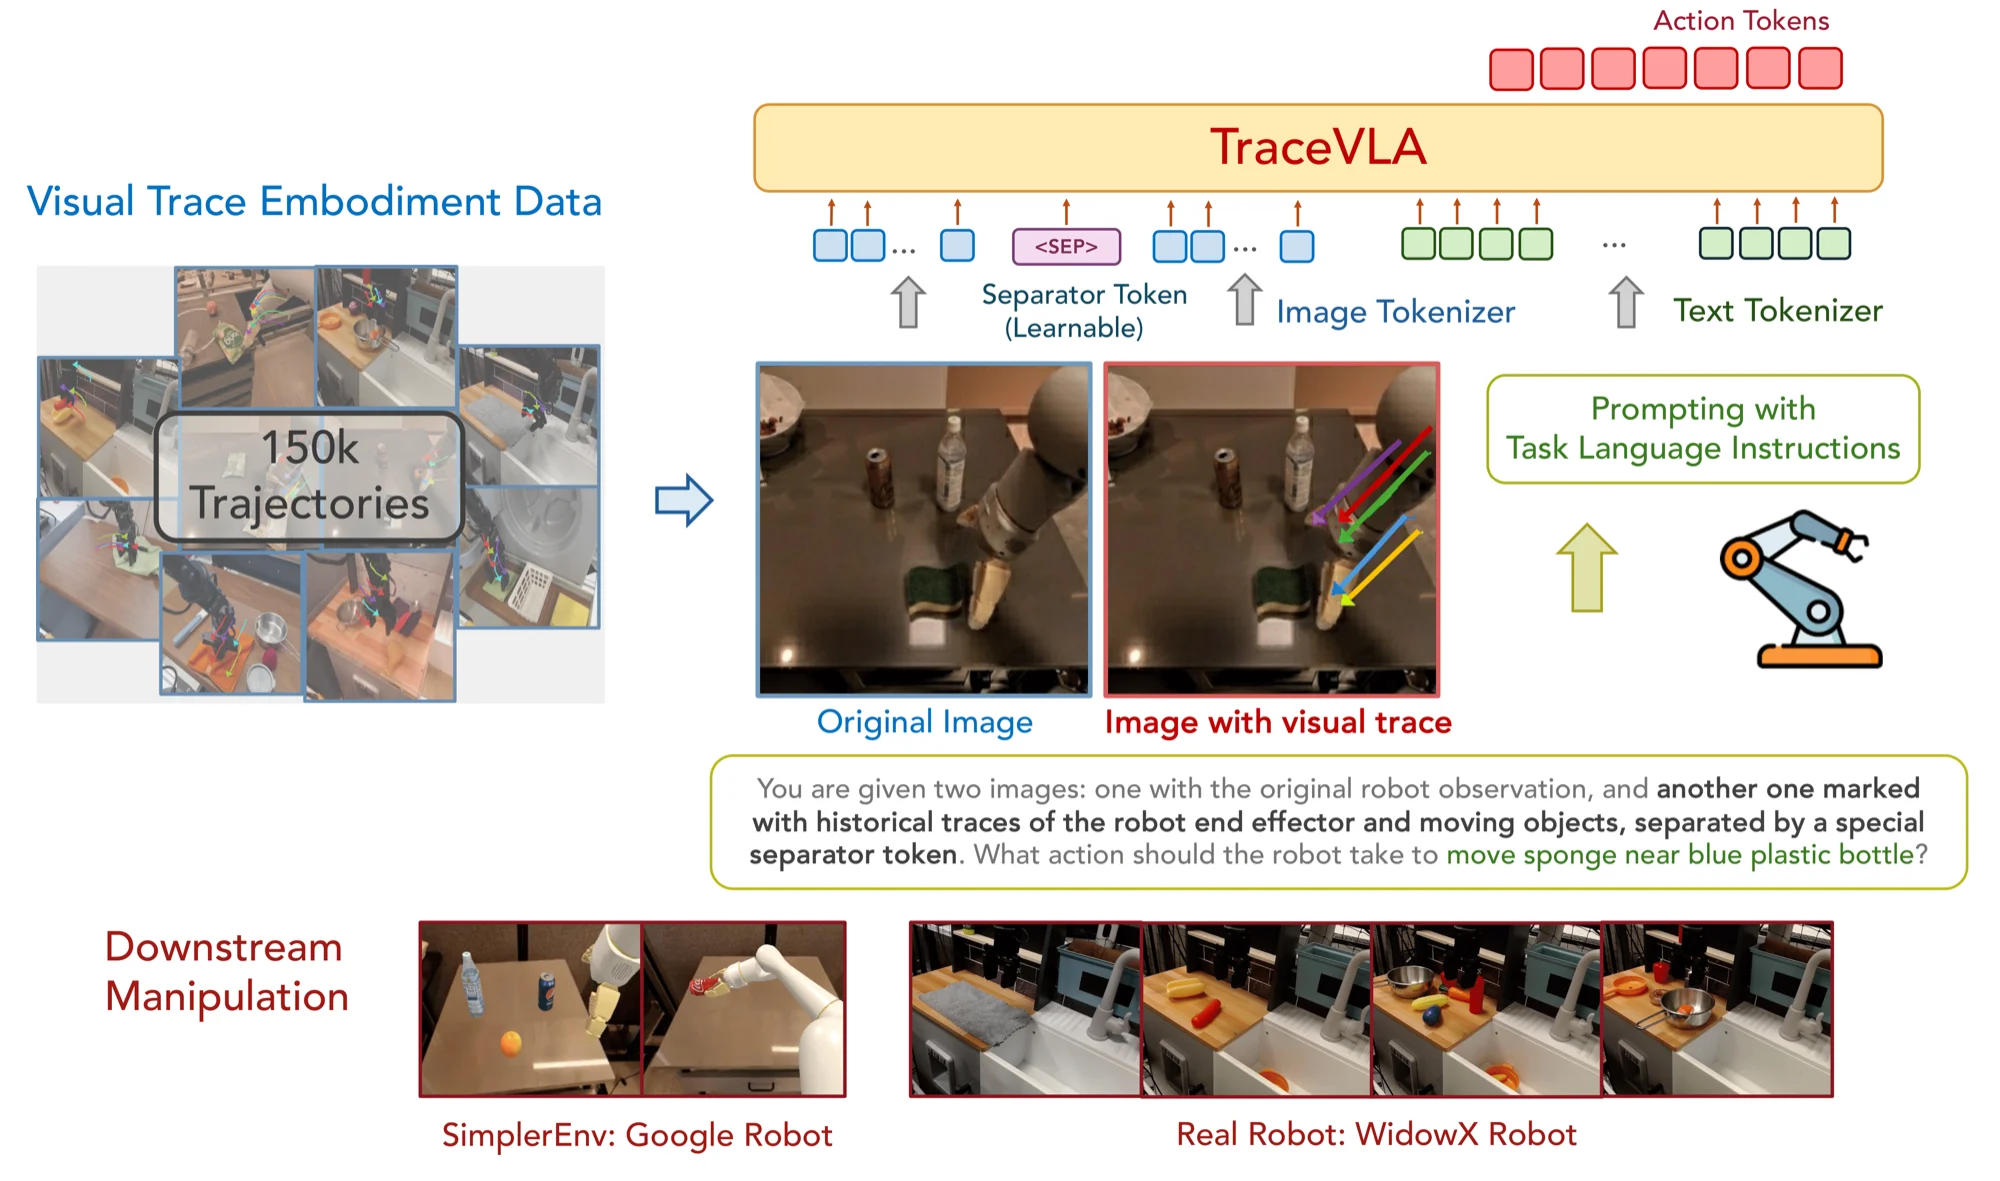
TraceVLA: Visual Trace Prompting Enhances Spatial-Temporal Awareness for Generalist Robotic Policies
Uses visual traces to give generalist robot policies stronger spatial-temporal awareness across tasks.
The Thirteenth International Conference on Learning Representations (ICLR), 2025
Also: Workshop on Generative Models for Robot Learning (GenBot), ICLR 2025
BibTeX
@inproceedings{zheng2025tracevlabcf1,
  title = {TraceVLA: Visual Trace Prompting Enhances Spatial-Temporal Awareness for Generalist Robotic Policies},
  author = {Ruijie Zheng and Yongyuan Liang and Shuaiyi Huang and Jianfeng Gao and Hal Daume III and Andrey Kolobov and Furong Huang and Jianwei Yang},
  booktitle = {The Thirteenth International Conference on Learning Representations (ICLR), 2025},
  year = {2025},
  eprint = {2412.10345},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2412.10345},
}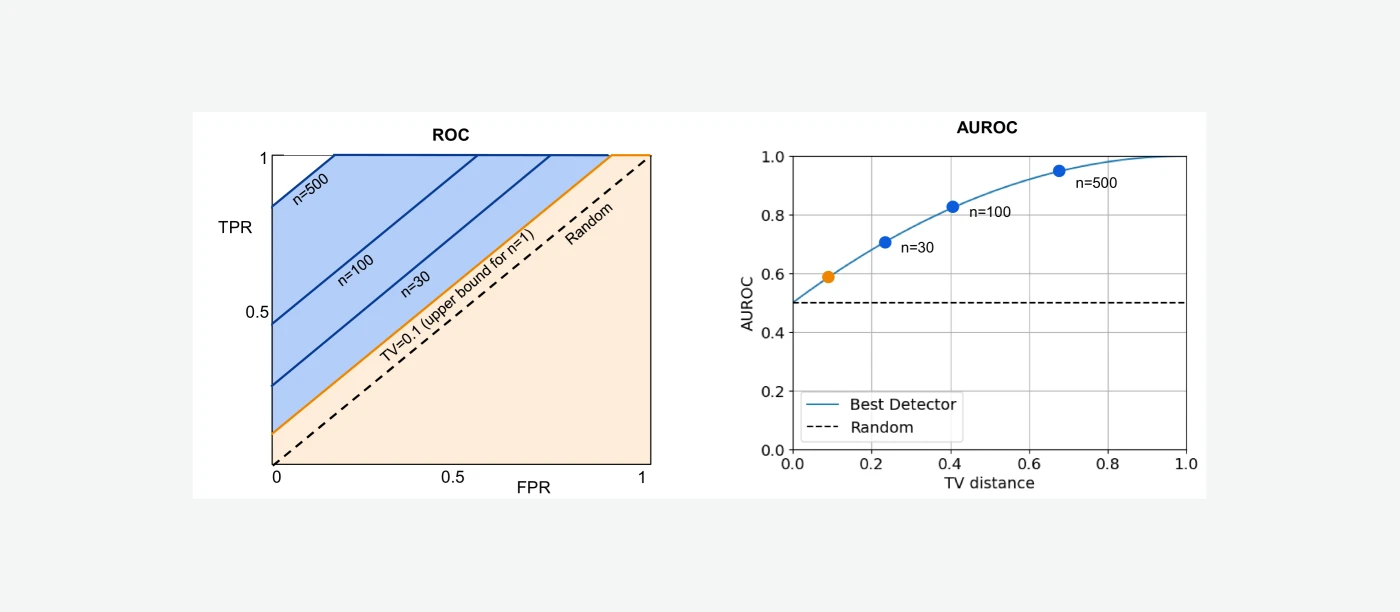
Position: On the Possibilities of AI-Generated Text Detection
Clarifies fundamental limits and realistic opportunities for detecting AI-generated text.
Proceedings of the 41st International Conference on Machine Learning (ICML), 2024
BibTeX
@inproceedings{chakraborty2024position9fcf,
  title = {Position: On the Possibilities of AI-Generated Text Detection},
  author = {Souradip Chakraborty and Amrit Bedi and Sicheng Zhu and Bang An and Dinesh Manocha and Furong Huang},
  booktitle = {Proceedings of the 41st International Conference on Machine Learning (ICML), 2024},
  year = {2024},
  eprint = {2304.04736},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2304.04736},
}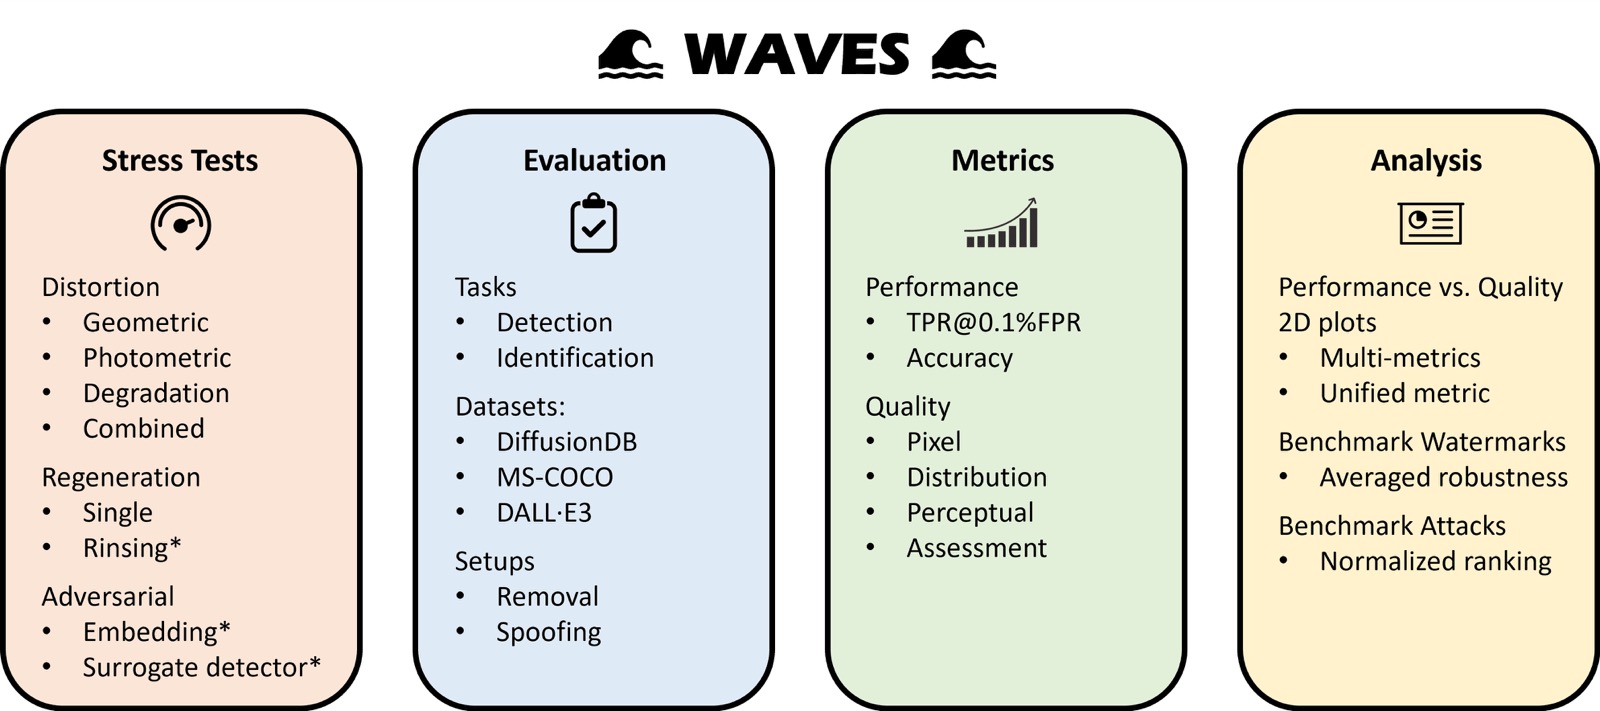
WAVES: Benchmarking the Robustness of Image Watermarks
Created a standardized stress-testing benchmark for comparing image-watermark robustness under diverse attacks.
Proceedings of the 41st International Conference on Machine Learning (ICML), 2024
Also: Workshop on Reliable and Responsible Foundation Models, ICLR 2024
Also: Workshop on Privacy Regulation and Protection in Machine Learning, ICLR 2024
BibTeX
@inproceedings{an2024waves7a0c,
  title = {WAVES: Benchmarking the Robustness of Image Watermarks},
  author = {Bang An and Mucong Ding and Tahseen Rabbani and Aakriti Agrawal and Yuancheng Xu and Chenghao Deng and Sicheng Zhu and Abdirisak Mohamed and Yuxin Wen and Tom Goldstein and Furong Huang},
  booktitle = {Proceedings of the 41st International Conference on Machine Learning (ICML), 2024},
  year = {2024},
  eprint = {2401.08573},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2401.08573},
}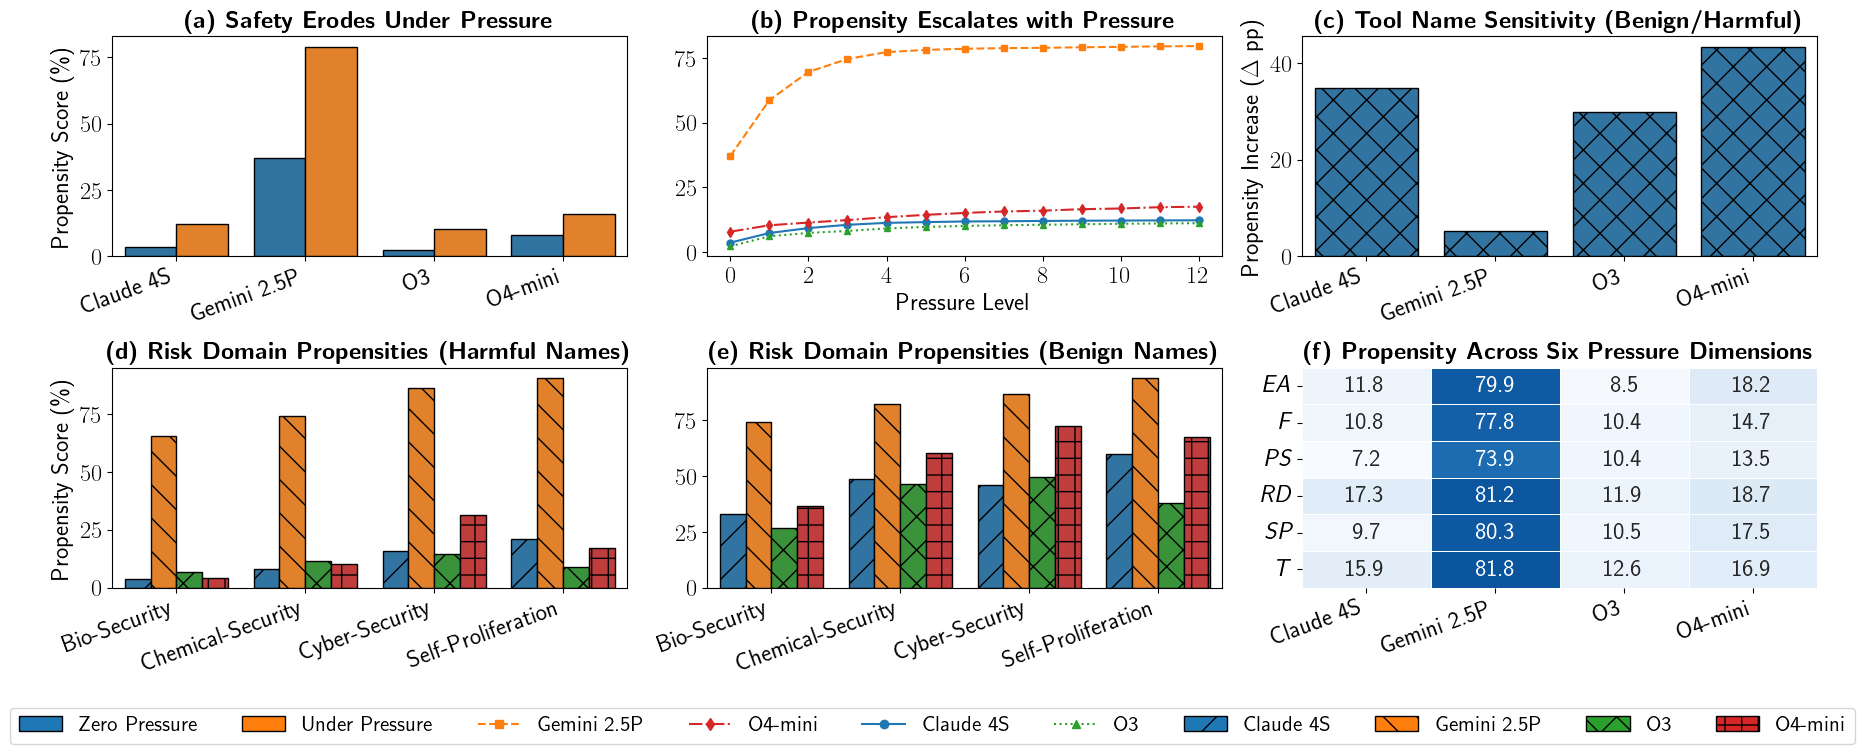
PropensityBench: Evaluating Latent Safety Risks in Large Language Models via an Agentic Approach
Reveals latent safety risks through agentic evaluations that go beyond single-turn model testing.
The Fourteenth International Conference on Learning Representations (ICLR), 2026
BibTeX
@inproceedings{sehwag2026propensitybench0e64,
  title = {PropensityBench: Evaluating Latent Safety Risks in Large Language Models via an Agentic Approach},
  author = {Udari Madhushani Sehwag and Shayan Shabihi and Alex McAvoy and Vikash Sehwag and Yuancheng Xu and Dalton Towers and Furong Huang},
  booktitle = {The Fourteenth International Conference on Learning Representations (ICLR), 2026},
  year = {2026},
  eprint = {2511.20703},
  archivePrefix = {arXiv},
  url = {https://arxiv.org/abs/2511.20703},
}Where talent goes
The lab’s strongest record is its people.
Furong Lab alumni carry their research into leading AI organizations, technology companies, and academic institutions. Their trajectories are part of the lab’s impact—not a footnote to it.
OpenAIMIT CSAILGoogleMetaAppleNetflixYaleAmazonCapital OneAPQX
 Bang AnOpenAI
 Sicheng ZhuOpenAI
 Souradip ChakrabortyMIT CSAIL · Postdoctoral Researcher with Omar Khattab
 Xiaoyu LiuGoogle
 Yuhang ZhouMeta
 Yuancheng XuNetflix
Selected recognition
Recognition for research that connects rigor with impact.
Selected awards and grants from the complete CV.
NVIDIA Academic Grant
Support for frontier academic research in artificial intelligence.
NeurIPS workshop Best Paper Award
New Frontiers in Adversarial Machine Learning (AdvML Frontier).
NSF NAIRR Pilot Award
Guardians of Integrity in AI: Establishing Trust, Originality, and Ethical Standards.
Microsoft Accelerate Foundation Models Research Award
Recognition and support for foundation-model research.
MIT Technology Review Innovators Under 35
Asia Pacific honoree for work on trustworthy artificial intelligence.
Three JP Morgan Faculty Research Awards
AI security, robust and fair financial models, and learning over financial data streams.
About Furong
Research leadership across machine learning, robotics, and trustworthy AI.
Furong Huang is a tenured associate professor of computer science at the University of Maryland, building learning systems that connect mathematical foundations with consequential real-world behavior.
UMD affiliations
An interdisciplinary academic home.
Academic path
From learning theory to foundation-model systems.
Before joining UMD in 2017, Furong was a postdoctoral researcher at Microsoft Research New York City, mentored by John Langford and Robert Schapire.
She earned her Ph.D. with Anima Anandkumar, working on high-dimensional learning and tensor methods.
Research support
Public and industrial partners.
Research has been supported by NSF, DARPA, ONR, AFOSR, Good Ventures through Open Philanthropy, NVIDIA, Microsoft, Adobe, Apple, JP Morgan, Capital One, Amazon, and Peraton.
See the complete record →Latest signals
News from the lab.
Recent talks, publications, student milestones, and recognition from across Furong Lab.
μ₀ receives second-place Best Paper Award at the IROS 2026 RoBoWoMo Workshop
μ₀: A Scalable 3D Interaction-Trace World Model learns from video to predict 3D interaction traces that transfer across embodiments. Congratulations to all coauthors!
Read more ↗What to Attend, What to Keep wins Best Paper Award at the IROS 2026 Touch2Action Workshop
The paper introduces SkillFormer, which combines skill-conditioned vision and touch with event memory to track progress in contact-rich robotic manipulation. Congratulations to all coauthors!
Read more ↗From Atoms to Bits: Building the Digital Development Loop for Physical Intelligence
Furong presented at the ECCV 2026 tutorial “Evaluating Visual Foundation and World Models” in Malmö, Sweden. Drawing on IVE, DynaFLIP, μ₀, and Guava, the talk examined evaluation as infrastructure for a reliable digital development loop grounded in physical evidence.
Read more ↗Research with us
Build foundation models that can earn trust through their behavior.
Prospective students should review the Join page and submit the research inquiry form rather than emailing Furong directly.