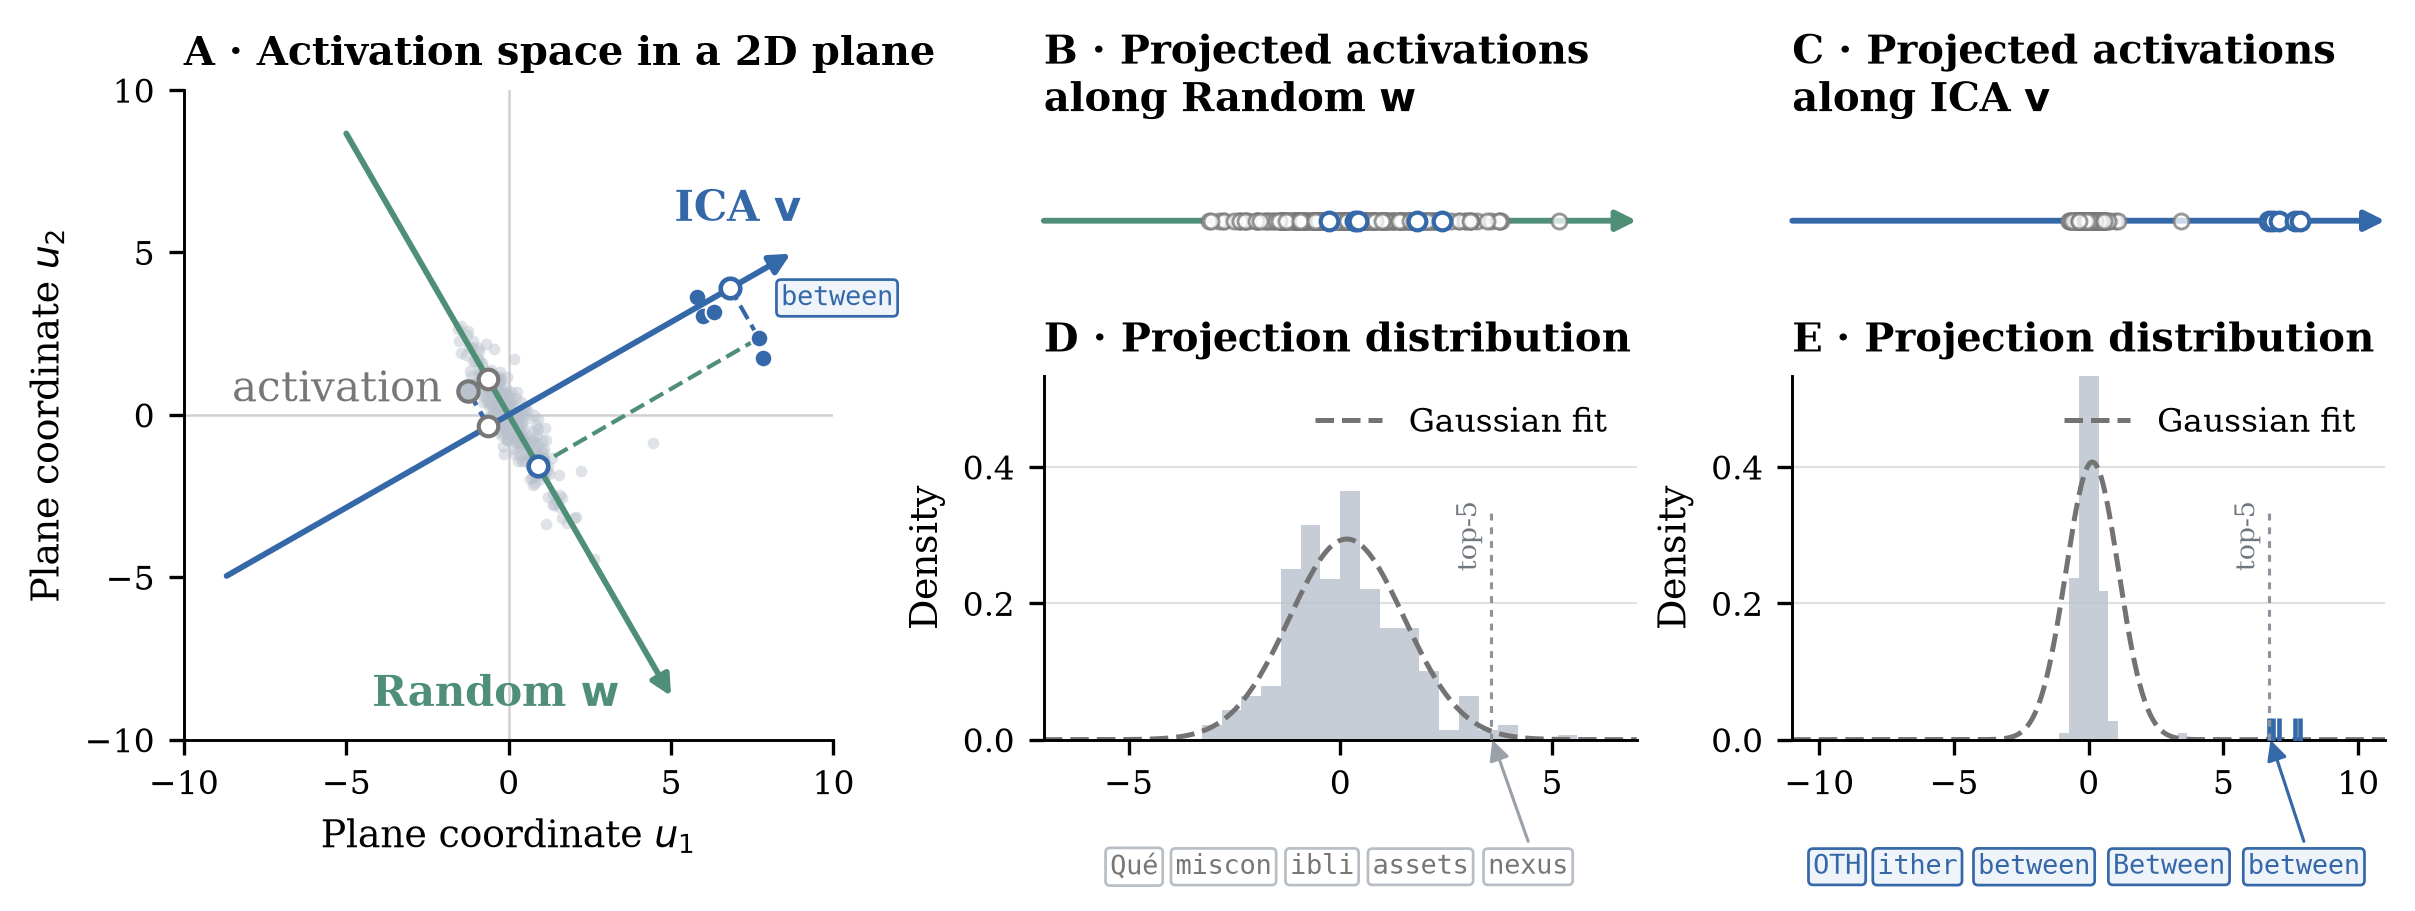
The following author-provided figures are reproduced unmodified. Responsive display preserves their full content and natural aspect ratios.
Non-Gaussianity Reveals Interpretable Directions in Language Models, by Sida Liu, Feijiang Han, Sarah Wiegreffe, and Furong Huang (2026).
Figure 1 conceptual illustration, from the official project figure. Paper and license notice. Licensed under CC BY-NC-ND 4.0. No changes made.
Fly-by-Code: Embodied Coding Agents for Aerial Manipulation with Active Visual and Physical Feedback, by Jaewoo Lee, Jeongyeon Seo, Sihyun Cho, Gyeongrak Choe, Yutong Wang, Bavin Saravanan, Jia-Bin Huang, Furong Huang, Sebastian Scherer, Guanya Shi, H. Jin Kim, Seungjae Lee, and Dongjae Lee (2026).
Figure 1 teaser, from the paper figure. Paper and license notice. Licensed under CC BY 4.0. No changes made.
Dex-One2Many: Learning Dexterous Manipulation from a Single Human Demonstration, by Jusuk Lee, Sungha Kim, Yeonsoo Park, Jonguk Cheon, Yoonkyo Jung, Yongjun You, H. Jin Kim, Jia-Bin Huang, Furong Huang, Youngseok Jang, and Seungjae Lee (2026).
Figure 1 teaser, from the paper figure. Paper and license notice. Licensed under CC BY 4.0. No changes made.